2229
As the robot DRC-HUBO from South Korea won the DARPA Robotics Challenge
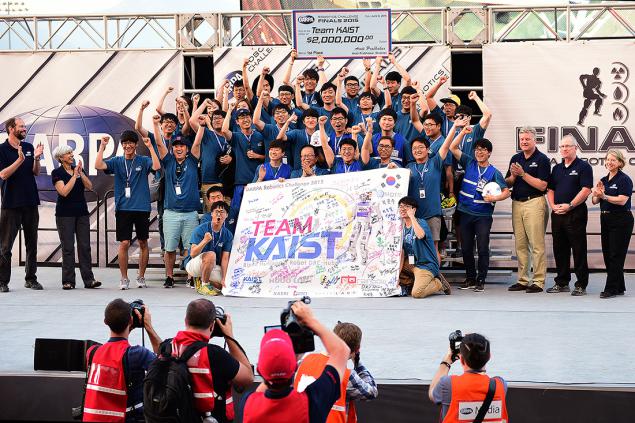
On Saturday, the team Korean leading scientific and technological institute (KAIST) DARPA Robotics Challenge (DRC) DRC-HUBO победил 22 other robots from five different countries and won the top prize of $ 2 million.
The ability to transform itself from a two-legged walking robot in the car on wheels has been instrumental in getting the award. Many robots have lost balance and fell to the ground, opening the door or by working with a drill. But do not DRC-HUBO
Moving on two legs [robot] is still not stable - said Jung Ho Oh, a professor of mechanical engineering at the Korea's leading scientific and technological institute, head of the team KAIST. - If one thing went wrong - the result can be catastrophic.Teams from the IHMC Boston Dynamics
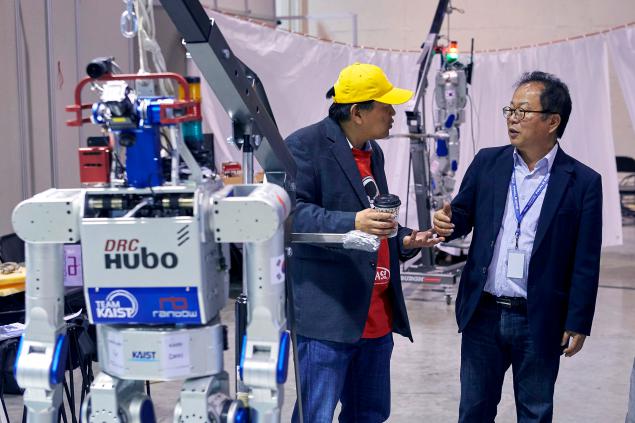
He said that the humanoid robot has advantages when working in the company of people, but he wanted to develop a design that minimizes the risk of falls, "I thought about many things, and it was very simple - the wheel on your lap".
< DRC-HUBO
< DARPA DRC соревнование DRC Finals were invited to the team, developing semi-autonomous robots and human operators have to work together on disaster simulation environment. Robots by universities and companies to compete very different in size and shape, some of them are robots with legs, wheels, as well as hybrids.
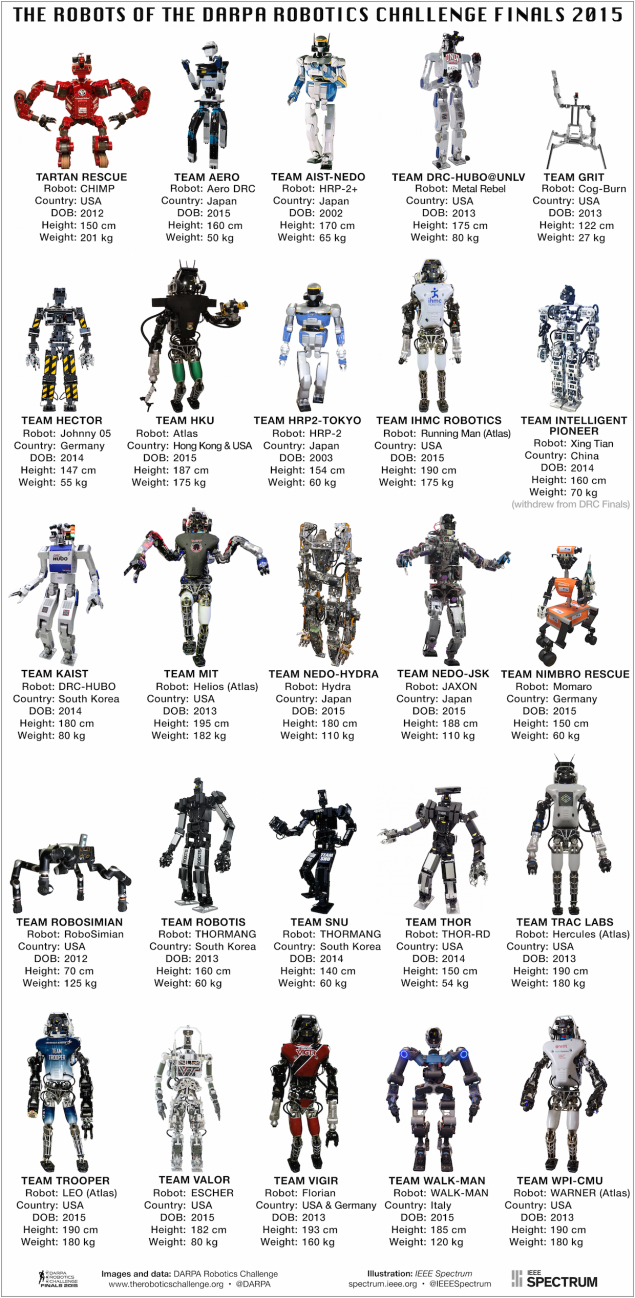
< DRC-HUBO Tartan Rescue CHIMP ATLAS
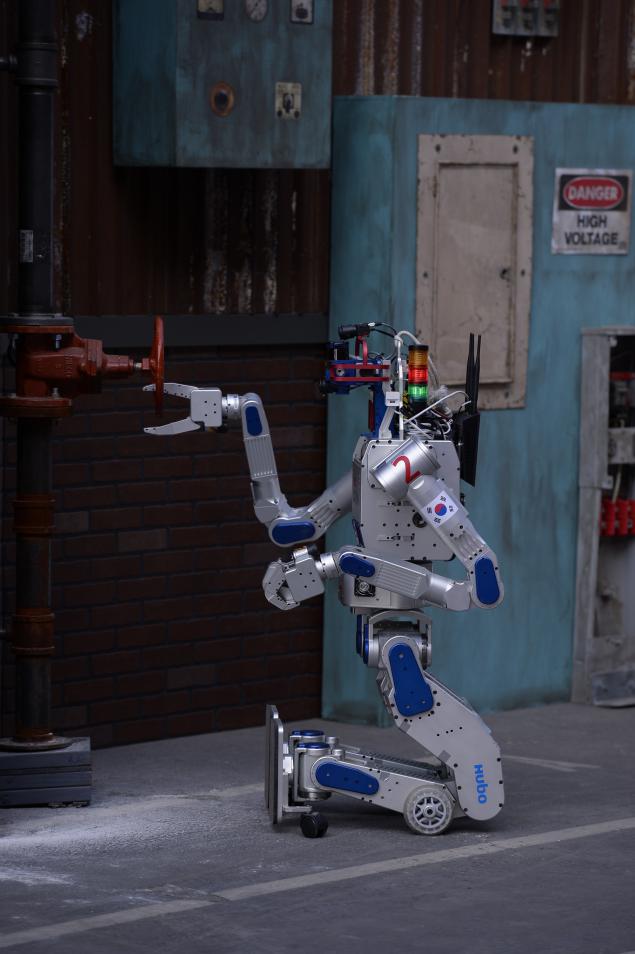
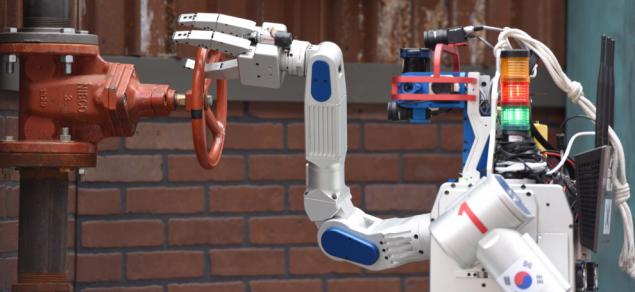
DRC-HUBO performs the task of closing the valve. Please note that the upper part of his body is rotated 180 degrees.
Flexibility - is the most important, - said the manager of DARPA and organizer DRC Jill Pratt meeting with journalists, commenting on the design of robots. - The robot, which is able to change the configuration from using the feet to the use of the wheels, can have a more complicated design and more weight, but it will give you this flexibility.
Professor O is an internationally recognized expert on the humanoid robot. He and his students from the KAIST in Daejeon (South Korea) to improve HUBO its platform for several generations. Below is a video that is already several years: when the professor makes Personal HUBO 2:
To DRC Finals DRC-HUBO KAIST DRC-HUBO
< 1. Wheels on the knees: DRC-HUBO
< 2. Powerful engines: SCHAFT DARPA приобретенный by Google , DRC-HUBO
< 3. Compatibility:
< 4. Rotary Torso: DRC-HUBO
< 5. Long arms: KAIST HUBO 2
< 6. Simplified sensing: ATLAS, for example), DRC-HUBO KAIST
< 7. Power:
< 8. Special software: PODO KAIST
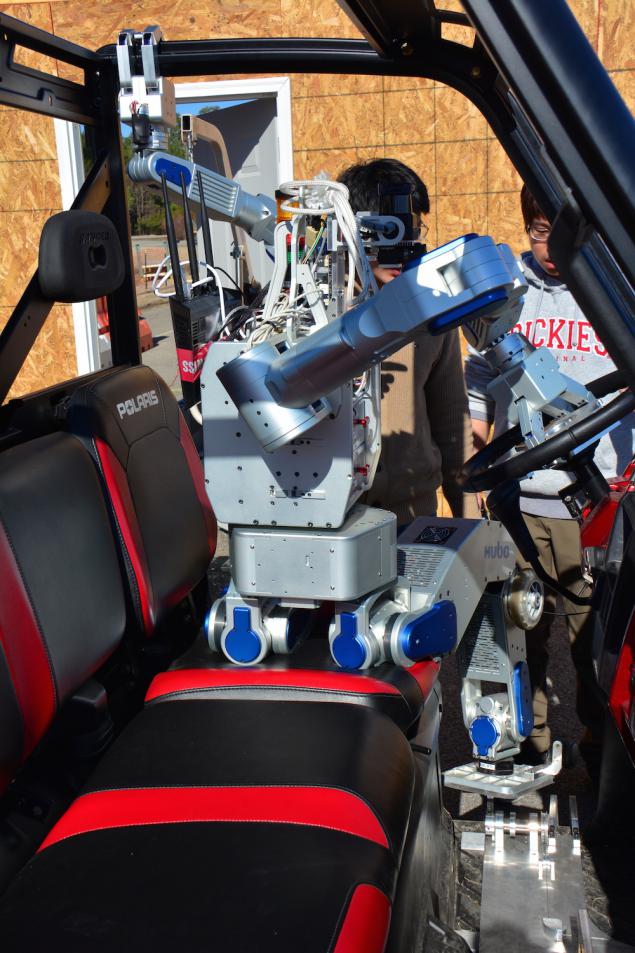
Now let's take a closer look DRC-HUBO KAIST
1. Setting on driving.
Teams are allowed to make modifications to the vehicle Polaris KAIST DRC-HUBO
2. Setting to get out of the vehicle.
It was one of the most difficult tasks. In preparation for it, Professor Oh, he told us, he came out of the car several times to understand what part of the body movement and uses it. He concluded that it would take a "dynamic approach". His team has programmed DRC-HUBO
About Professor said that while developing this movement burned a few engines, but the problem was solved by using the most powerful, specially manufactured engines. At the moment, the robot can leave the car in less than 4 minutes, and when he was on earth, he kneels down and leaves.
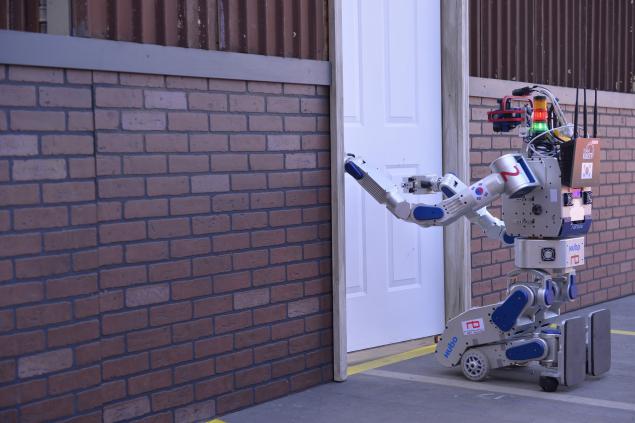
3. Setting the door.
Unlike other robots, which were to be (and to balance on two legs), to perform this task, DRC-HUBO
4. Setting a valve.
Note that at the beginning of the video lidar moves up and down to allow operators to scan the area in front of the robot. Then, when DRC-HUBO DRC-HUBO
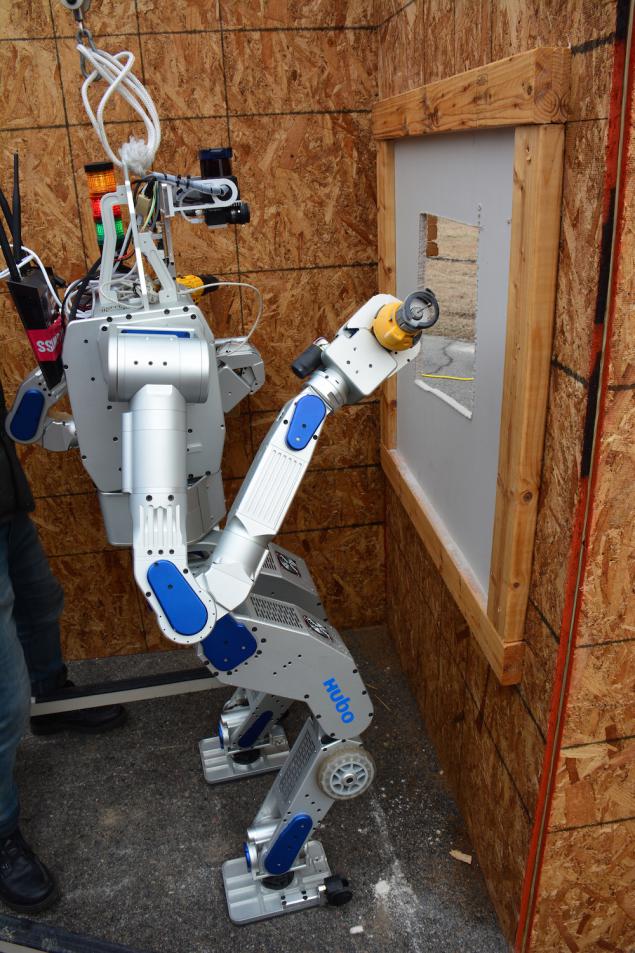
5. Specify the wall.
It was a difficult task for most teams, because the robot had to keep a drill and press the button incl. / Off. To use the device. < DRC-HUBO
6. Setting surprise.
This task consisted in to pull the plug and insert it into a different outlet. Notice how the DRC-HUBO
7. Setting for promotion through the rubble.
< DRC-HUBO
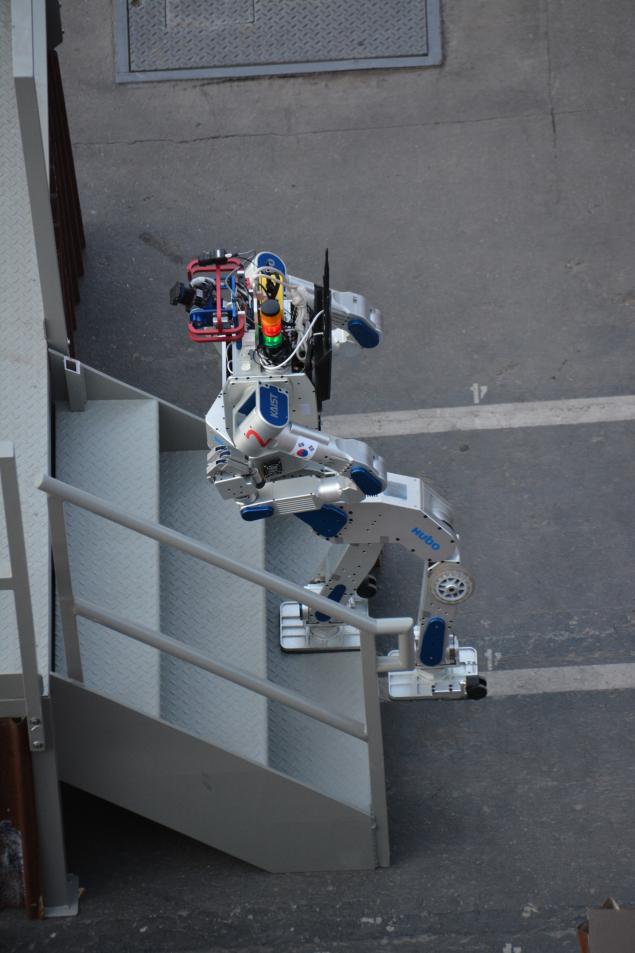
8. Setting in steps.
About Professor said that for many tasks, especially raising the stairs, it is important that the robot could see his legs. The large robot type ATLAS DRC-HUBO
< KAIST DRC-HUBO
He added that during the training they perform all tasks in both modes - standing and kneeling (the average time was 30 minutes). The team good at clearing the rubble hands DRC-HUBO DRC Finals , and they are also able to perform more complex tasks on the surface than the one that was in the competition.
It is a pity that we could not show all the ability of the robot in the competition ... it was all too easy! - сказал About Professor , down from the stage to the applause.
Source: geektimes.ru/company/robohunter/blog/251898/
In Amsterdam, the first bridge will soon be printed on 3D-printer
New images of Pluto from the station New Horizons