1463
Management roborukoy using leap motion
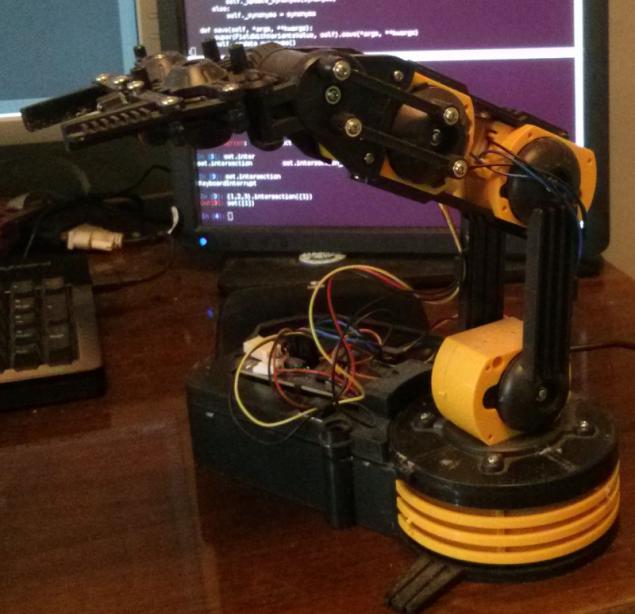
Last year I put together roboruku , wrote for her « driver » for linux, learn how to keep different items. And somehow forgot about it. But yesterday I brought leap motion and come up with a new idea - to learn to manage roborukoy by means of movements of his hands.
What you need to manage
We have roboruki:
- base - can be twisted clockwise and counter-clockwise; shoulder - to move up and down; elbow - move up and down; wrist - move up and down; claws - open and close.
& lt; code class = & quot; python & quot; & gt; from roboarm import Arm arm = Arm () arm.base.rotate_clock (3) arm.elbow.up (1) arm.grips.open (2) & lt; / code & gt;
The first implementation
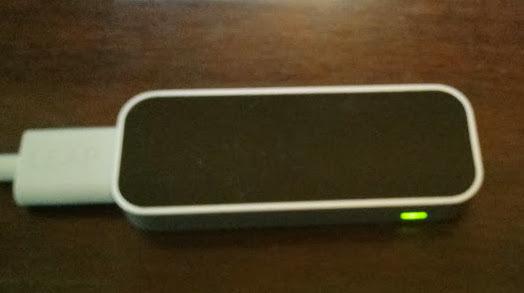
Leap motion can detect hands , fingers and their direction.
So I decided to tie the motion of the fingers:
Part roboruki My hand Number of fingers Axis Database Right 4 or 5 X Shoulder Left 4 or 5 Y Elbow Right 2 or 3 Y Wrist Any 1 Y < / Claws left 2 or 3 X
The second implementation
Leap motion gives the coordinates of the hands within certain limits, I have about -200 to 200 X and from 0 to 400 with respect to Y. This is an area I've broken into ten equal parts, and tied them to action:
Basis clockwise Leverage up Elbow up wrist up Open claws Basis counterclockwise Shoulder down Elbow down Wrist vvniz Close claws This realization was working = )
What happened
Video result where roboruka trying to raise the box:
A video where you can see hand movements better:
Links
Roboruka owi robotic arm.
Leap motion.
«Driver».
source code implementation.
Source: habrahabr.ru/post/214613/
What will the construction of its new Tesla "Gigafabriki"?
Troll-cybersquatters fined 32 thousand dollars

& lt; code class = & quot; python & quot; & gt; from roboarm import Arm arm = Arm () arm.base.rotate_clock (3) arm.elbow.up (1) arm.grips.open (2) & lt; / code & gt;
The first implementation
Leap motion can detect hands , fingers and their direction.
So I decided to tie the motion of the fingers:
| Part roboruki | My hand | Number of fingers | Axis | Database Right 4 or 5 X | Shoulder Left 4 or 5 Y | Elbow Right 2 or 3 Y | Wrist Any 1 Y < / | Claws left 2 or 3 X
The second implementation |
|---|
| Basis clockwise Leverage up Elbow up wrist up Open claws | Basis counterclockwise Shoulder down Elbow down Wrist vvniz Close claws This realization was working = ) What happened Roboruka owi robotic arm. Leap motion. «Driver». source code implementation. Source: habrahabr.ru/post/214613/
What will the construction of its new Tesla "Gigafabriki"?
Troll-cybersquatters fined 32 thousand dollars
|